Goal decomposition is the process of turning a complex objective into smaller tasks that an autonomous agent can execute. Within agent planning, it connects the desired outcome to an actionable sequence of sub-goals. IBM describes planning as including both a clear objective and the task decomposition needed to pursue it. IBM’s explanation of agent planning also describes agents anticipating future states and preparing structured action plans before execution.
The useful distinction is between producing a task list and using that list to guide action. An agent must be able to execute the subtasks, evaluate what happened, and adjust its plan. Decomposition supplies the structure for that process; it does not establish that the proposed steps are correct.
Why autonomous agents need goal decomposition
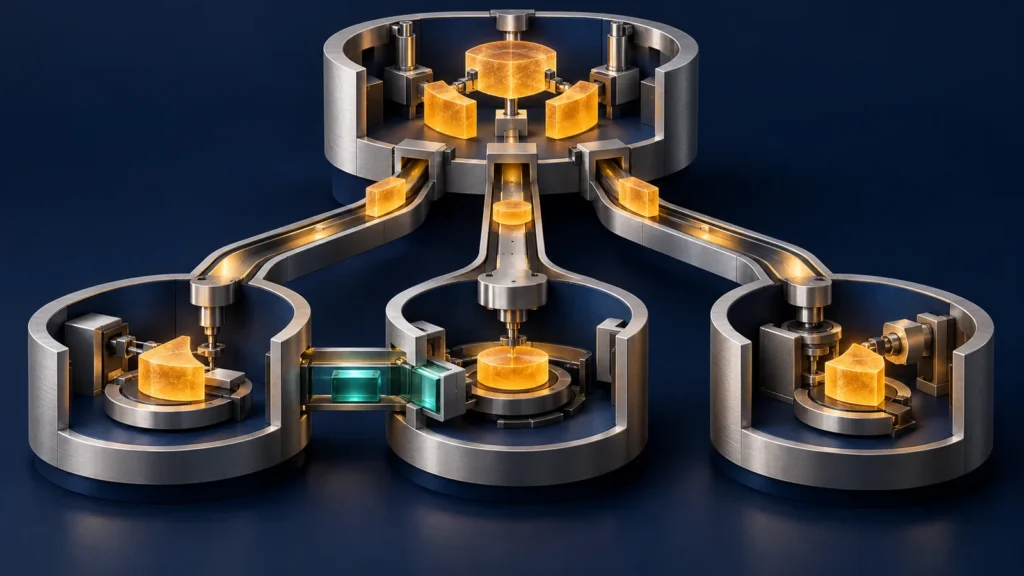
A complex objective leaves a practical question unanswered: what should the agent do next? Decomposition makes that question more manageable by separating an overall goal from the smaller actions needed to pursue it. A hierarchy organizes those levels: an objective contains sub-goals, which in turn can be broken into executable tasks.
Conceptually, the difference from a static workflow is where the sequence comes from. In a fixed sequence, the steps are specified in advance. In agent planning, the system generates a plan for the objective and can revise it in response to results. This distinction does not require every step to be autonomous. It concerns which decisions the agent makes about the work.
The practical value is adaptability. Relevance Lab’s description of agent development associates decomposition with adapting to unexpected states and recovering during execution. That is a capability claim, rather than a guarantee that any decomposed workflow will recover successfully.
How goal decomposition works
The supported planning process can be understood through five functional responsibilities. These describe what the system needs to accomplish, rather than prescribing separate software services.
- Establish the objective. Define the outcome that the plan is intended to achieve. Subtasks should remain connected to that objective.
- Generate sub-goals. Break the objective into smaller pieces that the agent can act on. Hierarchical decomposition concerns the relationship between those pieces and the larger goal.
- Arrange the actions. Turn the breakdown into a structured plan before execution. Planning includes anticipating future states, rather than considering each action in isolation.
- Execute the subtasks. Use the available means of action. IBM describes agents using APIs both to obtain real-time data and to carry out subtasks.
- Evaluate and adjust. Assess results and revise the plan when necessary. The supplied overview of goal decomposition describes this result-driven adjustment.
For an implementation review, these responsibilities provide a useful starting point: identify where the objective is represented, how the plan is generated, what executes it, and what evaluates the outcome. A component that proposes subtasks addresses only part of the workflow.
Planning methods and framework choices
Hierarchical decomposition, advance planning, and adaptive replanning describe different aspects of the process. They need not be mutually exclusive.
| Planning approach | Role in decomposition | Useful property | Boundary to assess |
|---|---|---|---|
| Hierarchical decomposition | Breaks an objective into smaller levels of work | Makes the relationship between the overall goal and subtasks explicit | A hierarchy alone does not demonstrate successful execution |
| Structured planning before execution | Arranges actions while anticipating future states | Gives multistep work an initial plan | The initial plan still needs evaluation against results |
| Adaptive replanning | Adjusts the plan as execution produces results or unexpected states | Supports recovery and adaptation | Recovery capability does not guarantee a successful outcome |
This comparison is most useful as a set of evaluation questions. A developer can ask a framework to demonstrate how it handles each responsibility, rather than treating the ability to generate a plan as evidence of the entire process.
IBM identifies planning algorithms and frameworks as part of agent planning, but the available evidence does not establish a comparison of specific implementations. It also does not substantiate particular named prompting techniques. A reliable recommendation therefore stops at these functional distinctions; it cannot rank libraries, prescribe prompt syntax, or claim that one technique performs best.
A practical walkthrough of the execution cycle
Consider the supported workflow at the point where a planned subtask needs current information. This is a conceptual walkthrough of the documented capabilities, rather than a reported deployment.
The agent first defines the objective and decomposes it into executable subtasks. It prepares a structured action plan, then uses an API to obtain the information needed for the relevant subtask. After execution, it evaluates the result in relation to the plan.
If the result leaves the objective unmet or introduces an unexpected state, the next responsibility is to reconsider the remaining plan. Replanning follows from evaluating the result; merely repeating the same action would not demonstrate that the plan had been revised. The evidence supports this general cycle, but does not specify an executable plan format or a particular failure-recovery algorithm.
Failures, state, and the limits of a plan
Observability matters because developers need to assess the agent during both decomposition and execution. Hugging Face’s material on agent observability and evaluation identifies monitoring agent performance as an important part of this work.
As engineering review questions, ask whether a proposed subtask is justified by the objective, whether execution produced the intended result, and whether a revision addresses what went wrong. These questions separate plan generation from evidence of progress.
Hallucinated subtasks, context window limits, repeated execution, and state management also belong in that review. What checks would reject an unjustified task? What information must remain available when the plan changes? What would stop an unsuccessful action from repeating indefinitely? These are design questions, not capabilities established by decomposition itself. No specific memory architecture, retry policy, loop limit, or context-management mechanism is established here.
What effective decomposition must demonstrate
For a developer assessing an agent, the meaningful demonstration extends through execution: show the objective, the proposed subtasks, their results, and the reason for any revision. A readable plan is a starting artifact. Whether the system can act on it and respond usefully to unexpected results remains the operational question.
Explore more AI Agents coverage.